
Projects
Engineering and academic projects
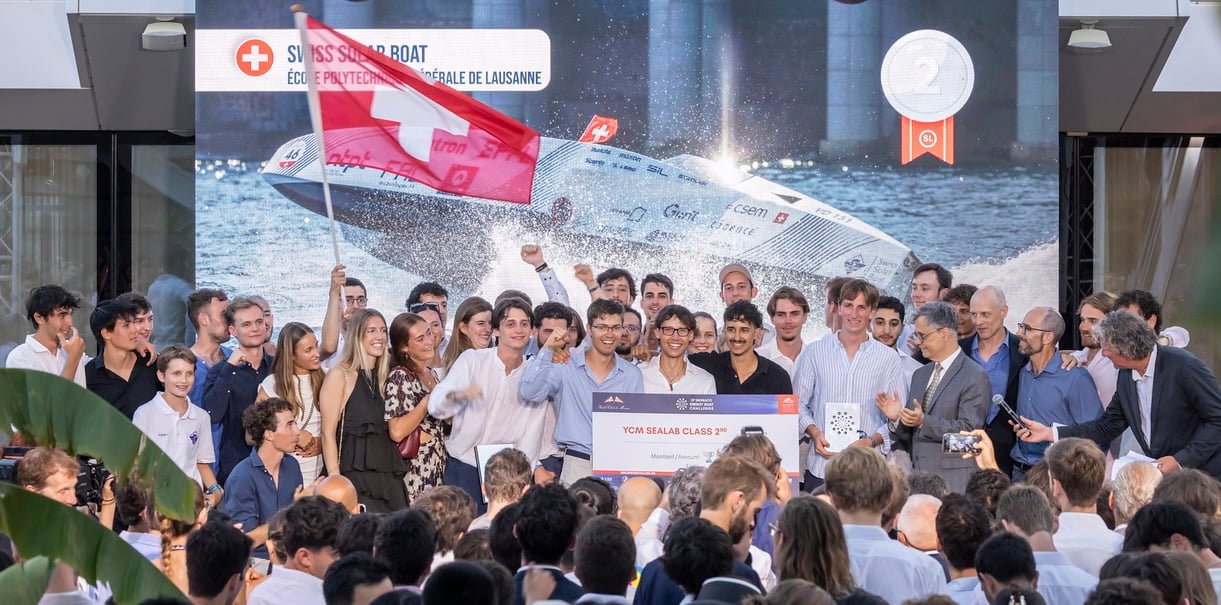
Swiss Solar Boat - World Champion at MEBC 2026
Safety-first Global Control Logic for a hydrogen-powered foiling boat
Robotics & Autonomous Control · Academic
Context (The Why)
SSB's new hydrogen-powered foiling boat, the Lobst'air, needed one global control logic to unify all its subsystems into a safety-first system ready for on-water testing and for winning the 2026 Monaco Energy Boat Challenge.
Solution (The What)
A hierarchical, safety-first finite state machine that governs every subsystem of the Lobst'air, running in real time on the boat's onboard computer.
My Implementation (The How)
Built a modular MATLAB Simulink/Stateflow architecture, compiled to C++ and deployed on a Speedgoat target computer.
Role
Duration: Spring 2026
Software Architecture & Integration Lead
Cochlear Implant Insertion Mechanism
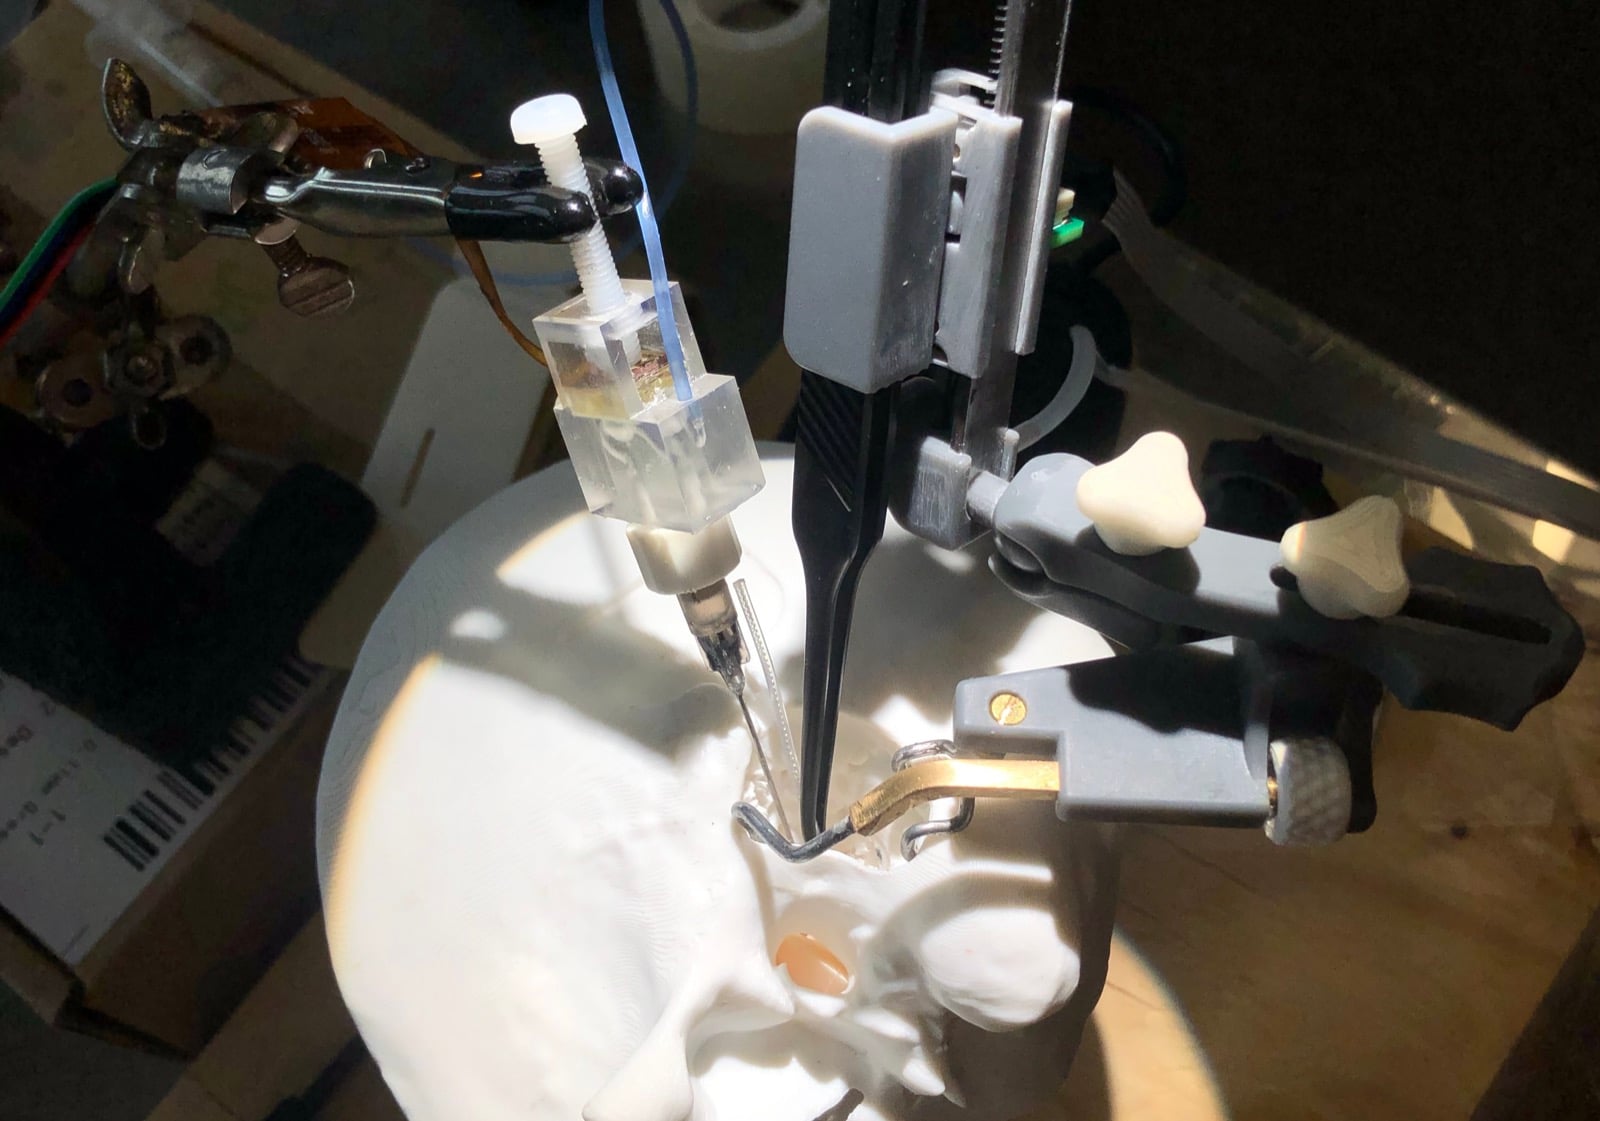
Force-sensing insertion mechanism for cochlear implant surgery
Biomedical & Precision Instrumentation · Professional
Context (The Why)
Cochlear implant insertion is done by feel, with no objective measurement of the force applied to the fragile scala tympani. The lab's prototype for studying this needed a simpler, more reliable redesign.
Solution (The What)
A redesigned, force-instrumented insertion mechanism for cochlear implant electrodes, SLA 3D-printed and flexure-guided.
My Implementation (The How)
Iterated SLA-printed prototypes of the force-sensing parallel-blade table, characterized the load cell, then wrote ESP32 firmware for foot-pedal-controlled insertion and validated it on 3D-printed cochlea and skull models.
Role
Duration: Spring 2025
R&D Engineer, Medical Devices
Motion Focus
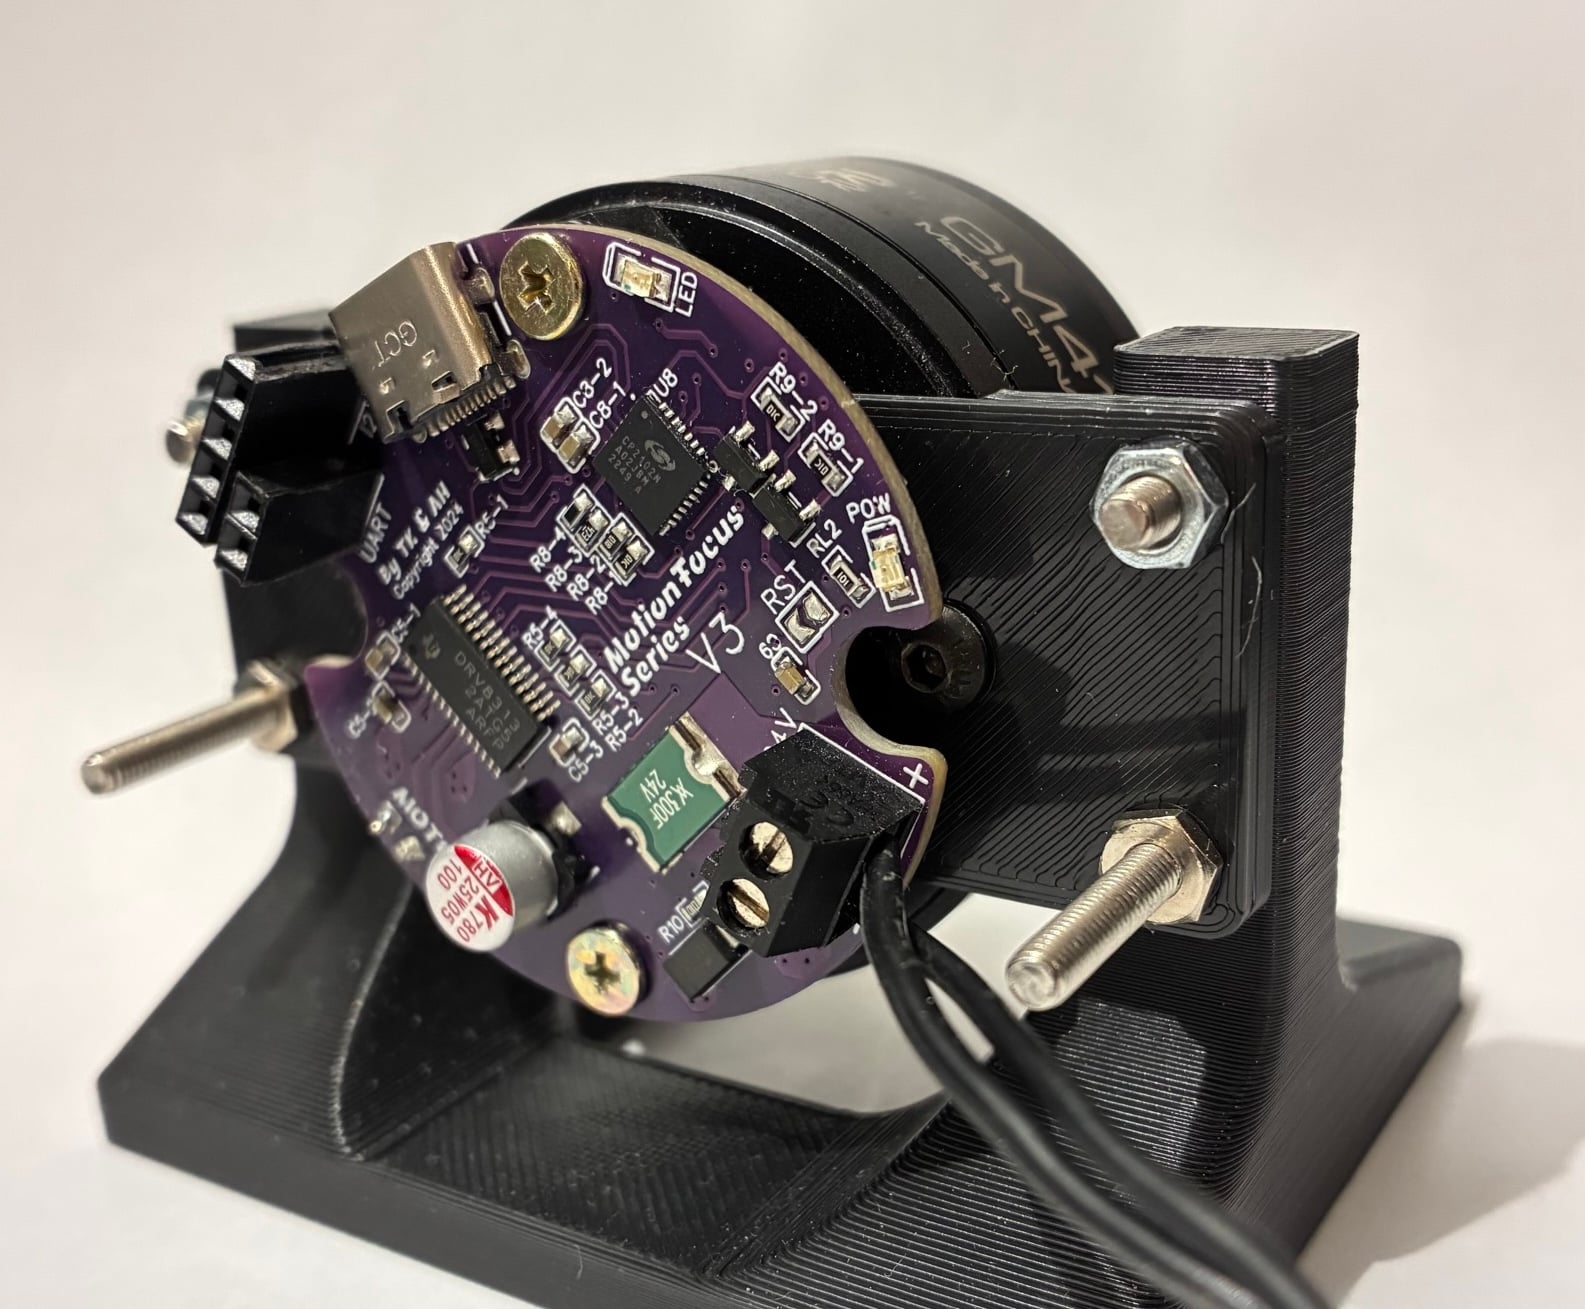
Plug-and-play actuator for rapid prototyping
Embedded Systems & Electronics · Personal
Context (The Why)
Off-the-shelf brushless motors need a separate driver, encoder, and firmware wired up before they can even spin. Motion Focus puts all of that electronics directly on the motor.
Solution (The What)
A four-layer PCB that mounts on a BLDC motor and turns it into a self-contained, commandable actuator. Closed-loop torque, velocity, and position control at 24V over USB-C, Bluetooth, or WiFi via an onboard ESP32.
My Implementation (The How)
Iterated through three PCB revisions and a FOC firmware adapted from SimpleFOC to reach a stable V3, then explored its startup potential in EPFL's Technology Ventures I course before starting its transition to open source.
Role
Duration: 2024 – 2026
Co-Founder & Lead Engineer
MPC Rocket Landing Controller
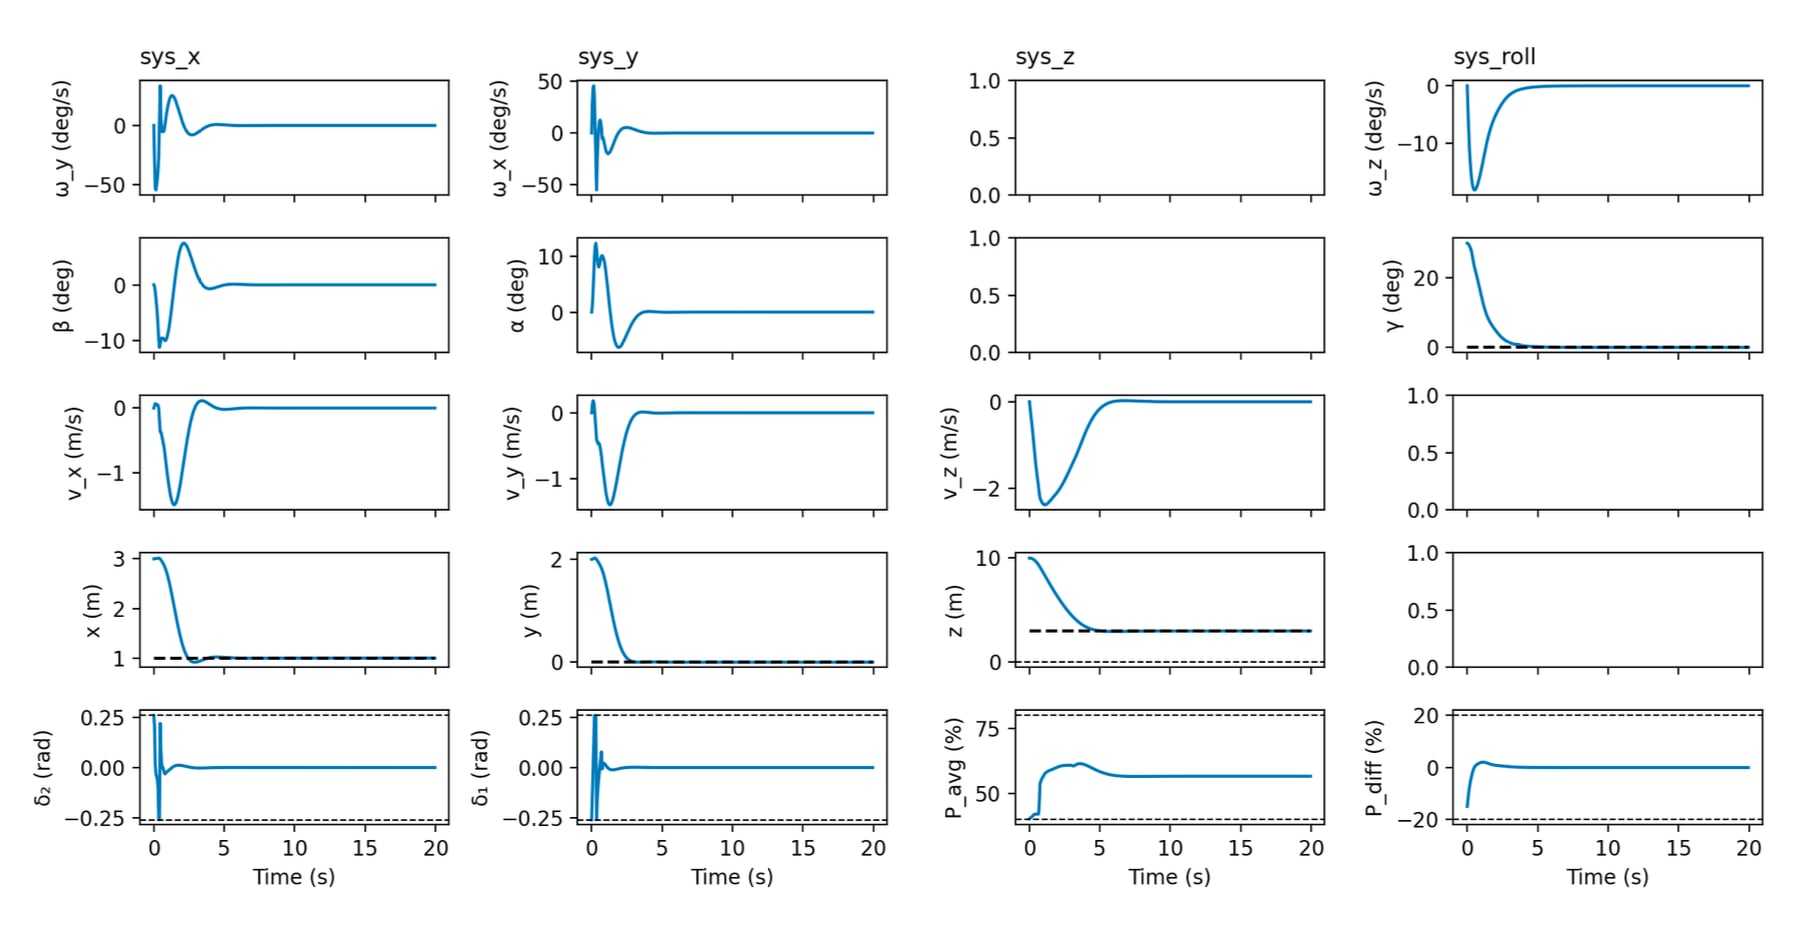
Model Predictive Control that lands a thrust-vectored rocket vertically.
Robotics & Autonomous Control · Academic
Context (The Why)
SpaceX turned the dream of vertical rocket landings into reality. This course allowed us to understand how it works.
Solution (The What)
A complete set of MPC controllers (nominal, offset-free, robust tube, and nonlinear) that fly a 12-state rocket model to a stationary vertical landing in simulation.
My Implementation (The How)
Linearized and decoupled the rocket dynamics into four subsystems, designed constrained LQR-MPC controllers for tracking, then added a disturbance observer, a robust tube-MPC, and a nonlinear MPC for comparison.
Role
Duration: Fall 2025
MPC Controller Design (Course Project)
CanSat - EPFL Spacecraft Team
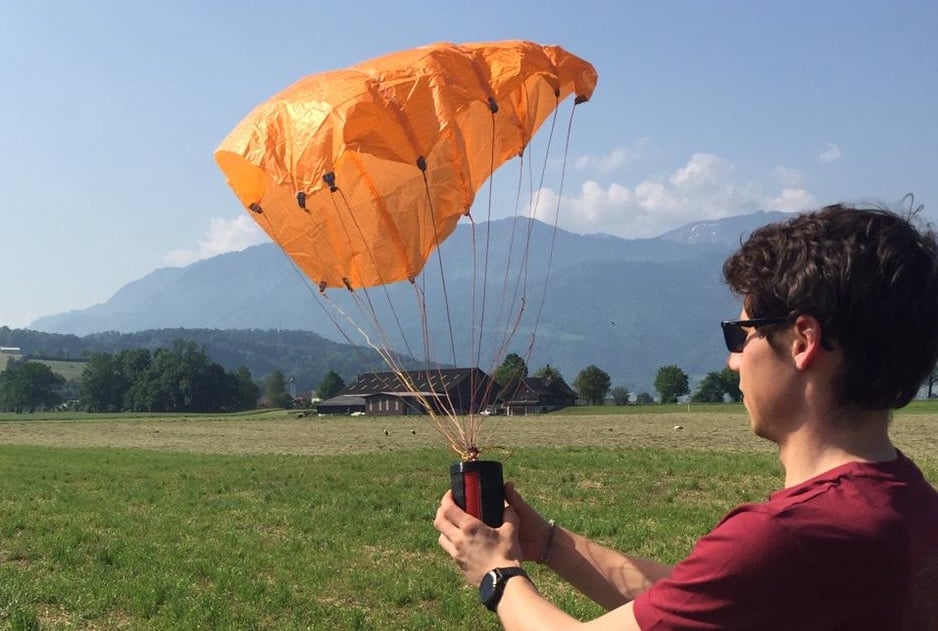
A can-sized satellite recovered by a self-built Rogallo parachute, launched twice from a student rocket.
Embedded Systems & Electronics · Academic
Context (The Why)
Students need to put theory into practice. CanSat was our chance to learn embedded electronics and project management hands-on.
Solution (The What)
Building El Tonio, a soda-can-sized satellite that had to survive a rocket launch to ~500 m and return environmental measures, over a full academic year.
My Implementation (The How)
Made a custom PCB built around a Raspberry Pi Zero, engineered a ground station for real-time data transmission, cut and sewed the Rogallo parachute in-house, validated it with drone drop tests, then flew it on two rocket launches.
Role
Duration: 2022 – 2023
Avionics & Recovery Engineer
Twocan PCB Assembly - EPFL Spacecraft Team
Three-day precision integration marathon to send a flight computer to space.
Embedded Systems & Electronics · Academic
Context (The Why)
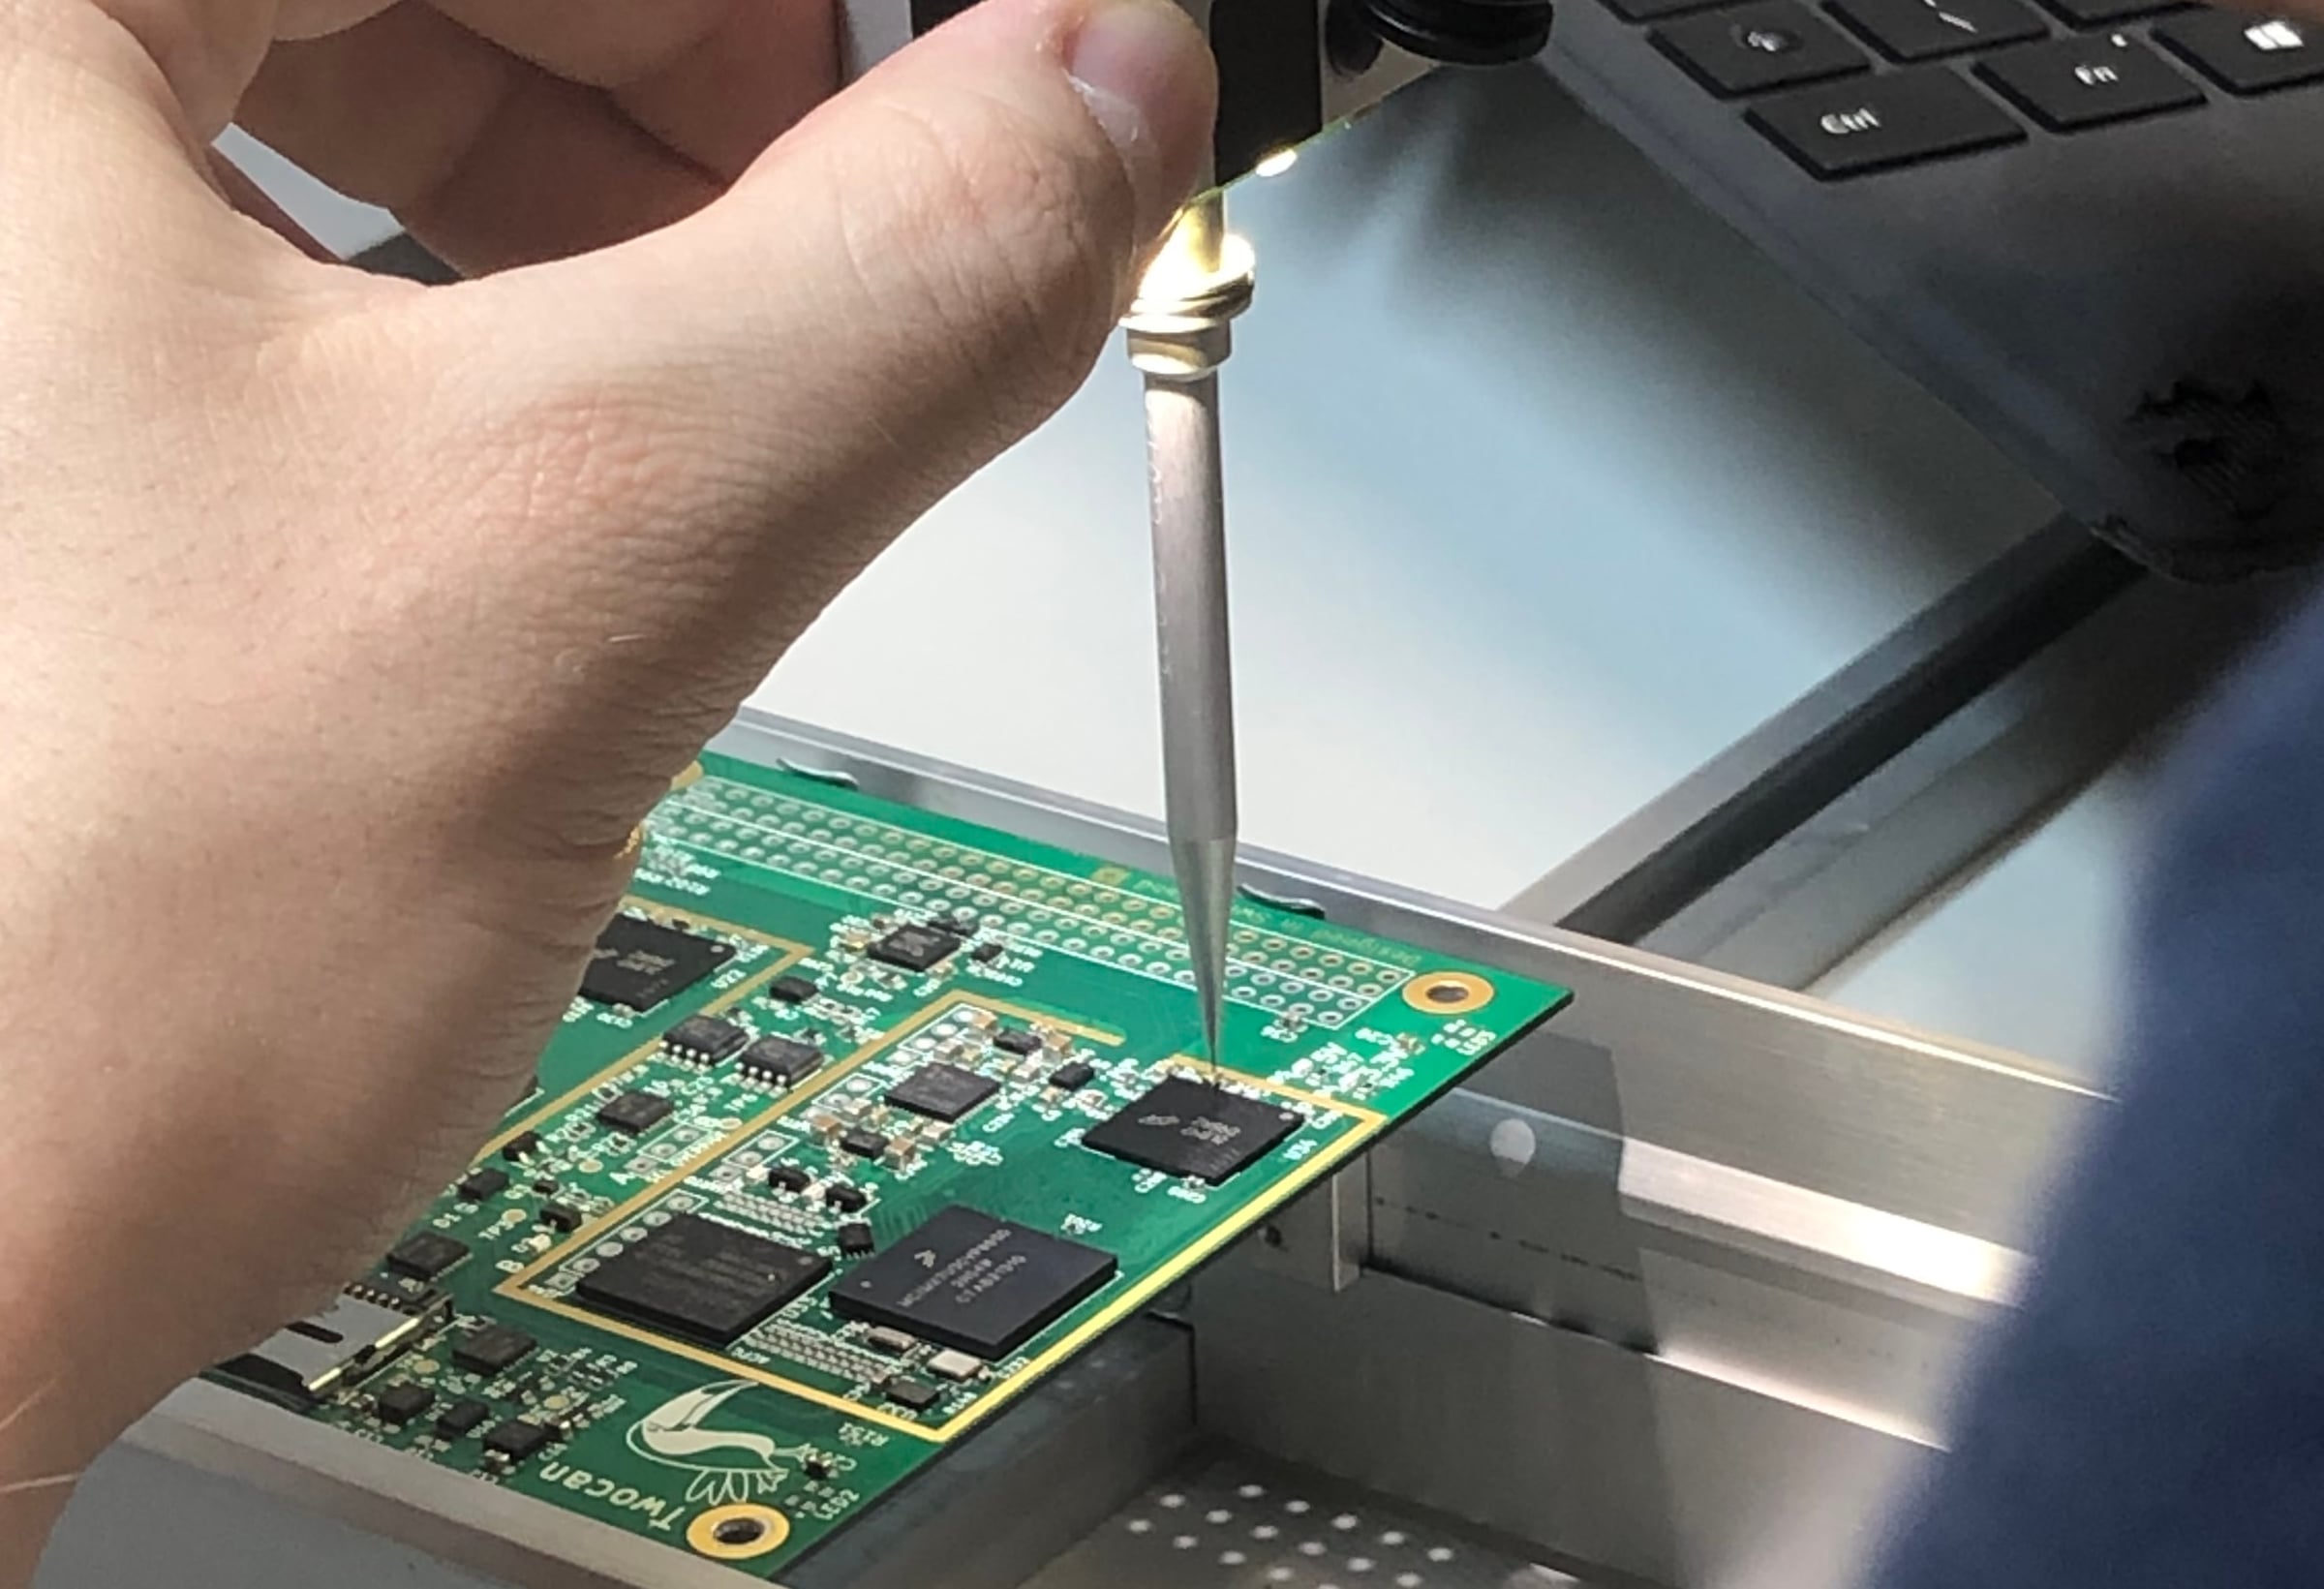
EPFL Spacecraft Team had just designed a new onboard flight computer, and it needed to be assembled.
Solution (The What)
A hand-assembled Twocan flight computer PCB, verified functional and later flown to space.
My Implementation (The How)
Ran the complete SMT assembly process by hand over three continuous days with three teammates rotating in shifts to keep concentration and precision high throughout.
Role
Duration: Spring 2024
Flight Hardware Assembly Technician
La Raclonette
Turning a campfire into a raclette station.
Mechanism Design & Fabrication · Personal
Context (The Why)
Grilling sausages over a wood fire got repetitive. We wanted to melt raclette straight over the embers instead.
Solution (The What)
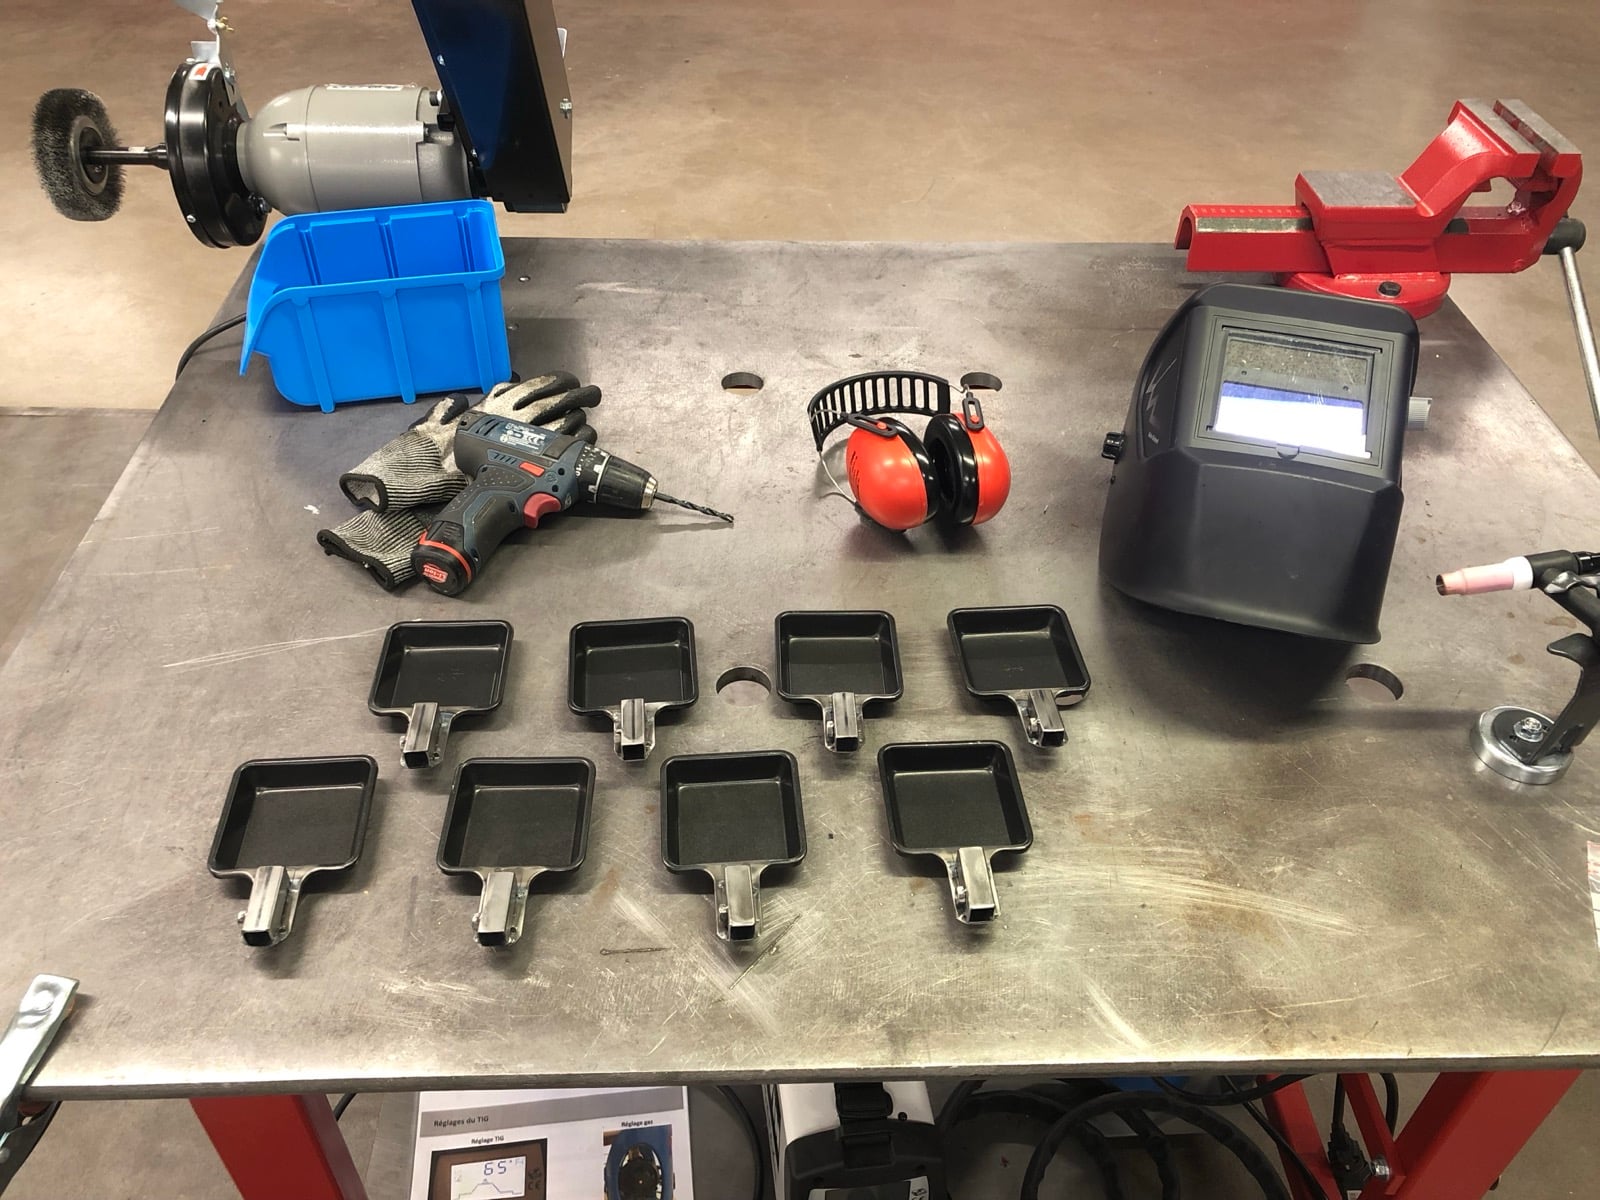
A small raclette pan on a screw-in handle that clips onto a stick, sold as a self-produced student micro-business.
My Implementation (The How)
Hand-built each pan and clamp from TIG-welded sheet steel in a home garage, then sold more than 50 units through a self-built website and Instagram shop.
Role
Duration: 2022 – 2024
Co-Founder — Design, Fabrication & Sales
Autonomous Navigation for a Thymio Robot
A camera-guided planner, Kalman filter, and reactive obstacle avoidance for a Thymio robot.
Robotics & Autonomous Control · Academic
Context (The Why)
EPFL's Basics of Mobile Robotics course tasked teams with building a complete autonomous navigation stack for the Thymio robot.
Solution (The What)
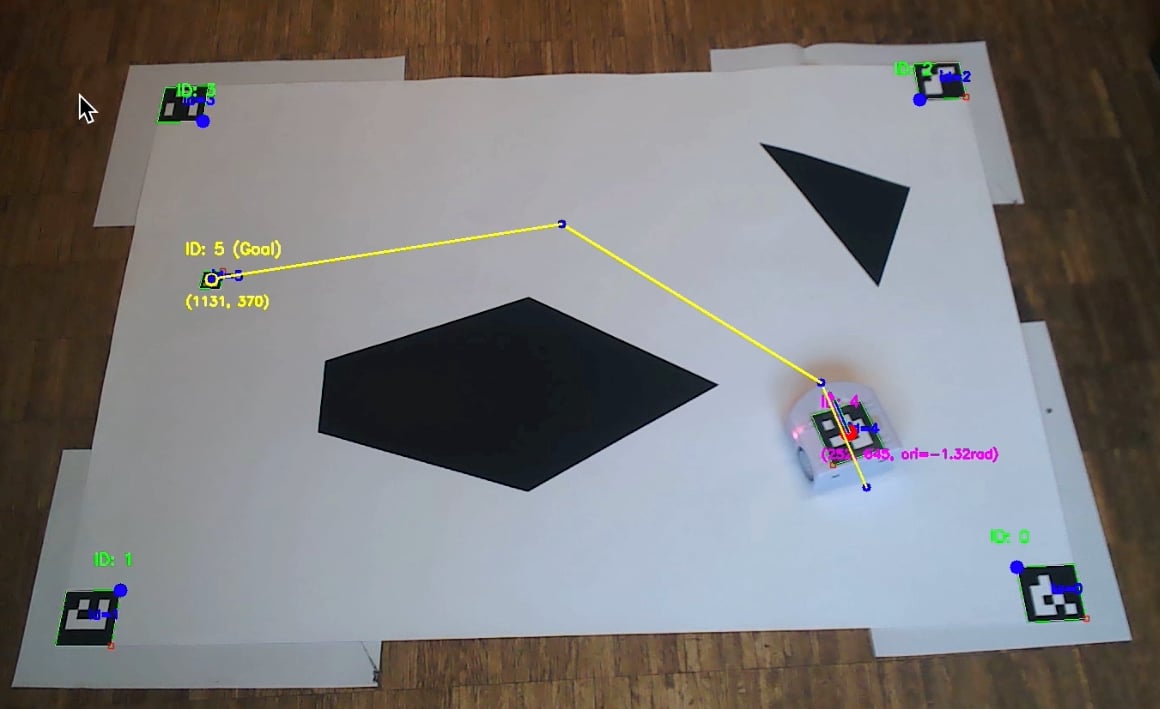
An autonomous navigation system letting a Thymio robot reach any goal on a marked arena, combining a visibility-graph planner, an Extended Kalman Filter, and reactive obstacle avoidance.
My Implementation (The How)
Built in Python with ArUco localization, a Dijkstra planner, and a 5-state EKF fusing camera pose with wheel odometry, tuning its noise from calibration runs.
Role
Duration: Fall 2025
Robotics Team Lead (Course Project)
DYNABAL - Balanced Dynamometer
A flexure-guided force sensor built to resolve sub-10-nanonewton forces.
Biomedical & Precision Instrumentation · Academic
Context (The Why)
EPFL's Mechanism Design II course tasked teams with building a miniaturized, flexure-only force sensor able to resolve forces down to 500 nN while staying insensitive to acceleration.
Solution (The What)
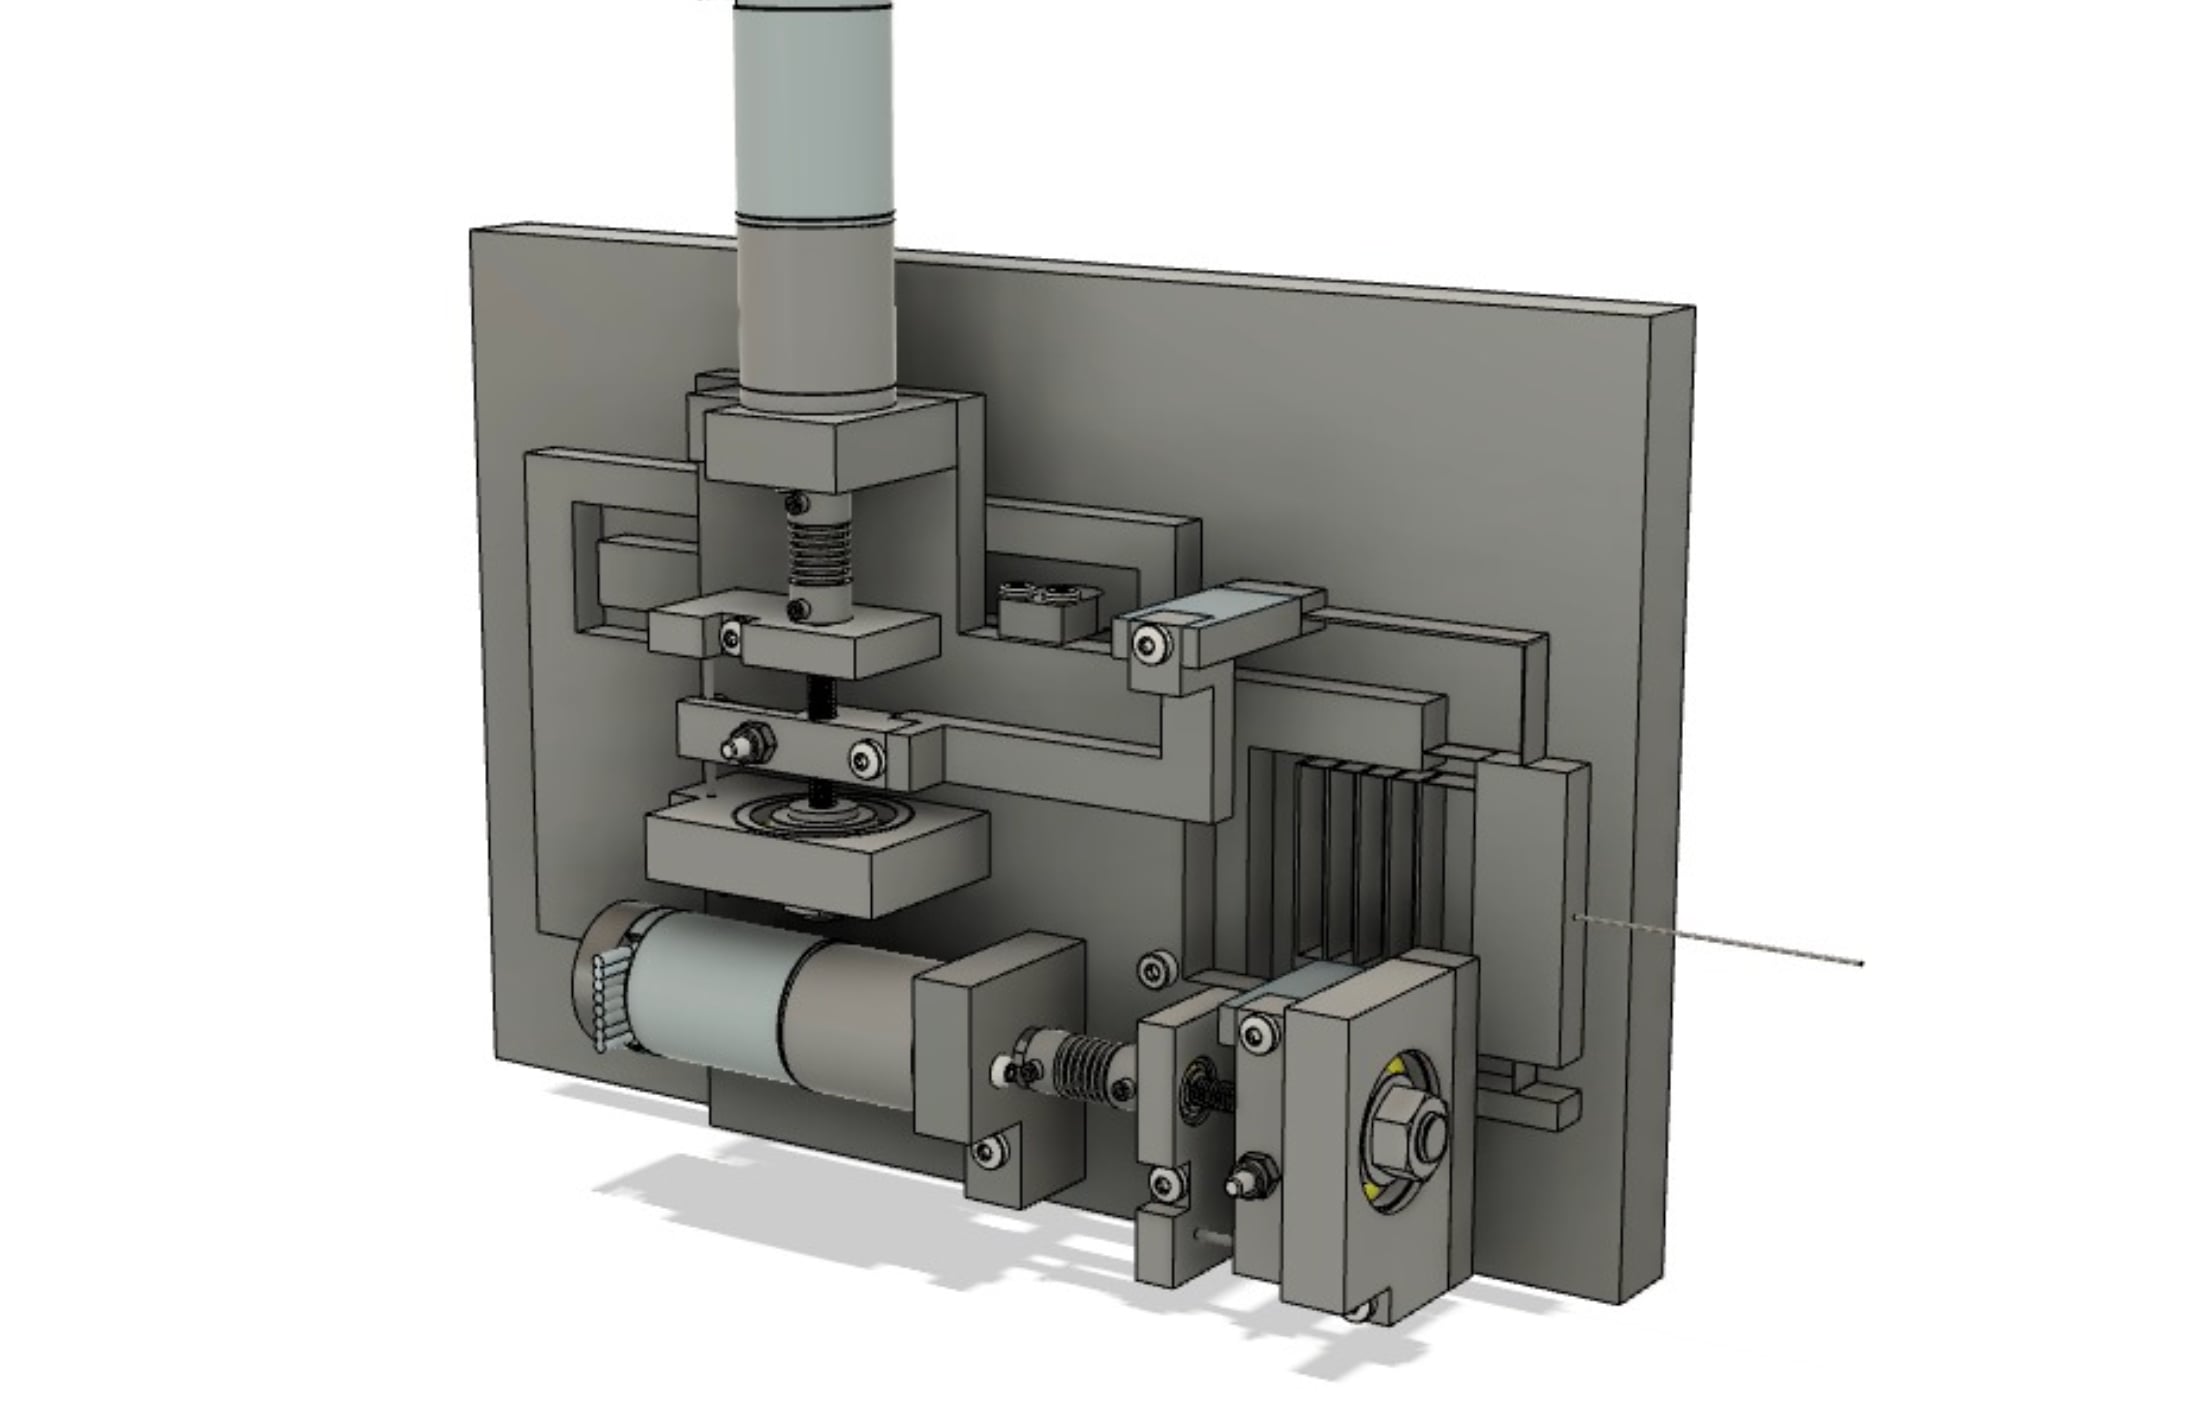
A compliant force sensor whose flexure-guided proof body is preloaded by a five-blade parallel-spring stage to tune its stiffness toward zero, read out capacitively, and balanced against gravity and acceleration.
My Implementation (The How)
Modeled the proof body's stiffness and energy analytically across crossed-blade pivots and two lead-screw-driven stages.
Role
Duration: Spring 2023
Flexure Design & Analysis (Course Project)
L'Épluche-Carotte
A hand-cranked mechanism that peels a carrot's full length in one motion.
Mechanism Design & Fabrication · Academic
Context (The Why)
EPFL's Construction Mécanique II course tasked teams with designing a fully hand-powered carrot peeler ready for production.
Solution (The What)
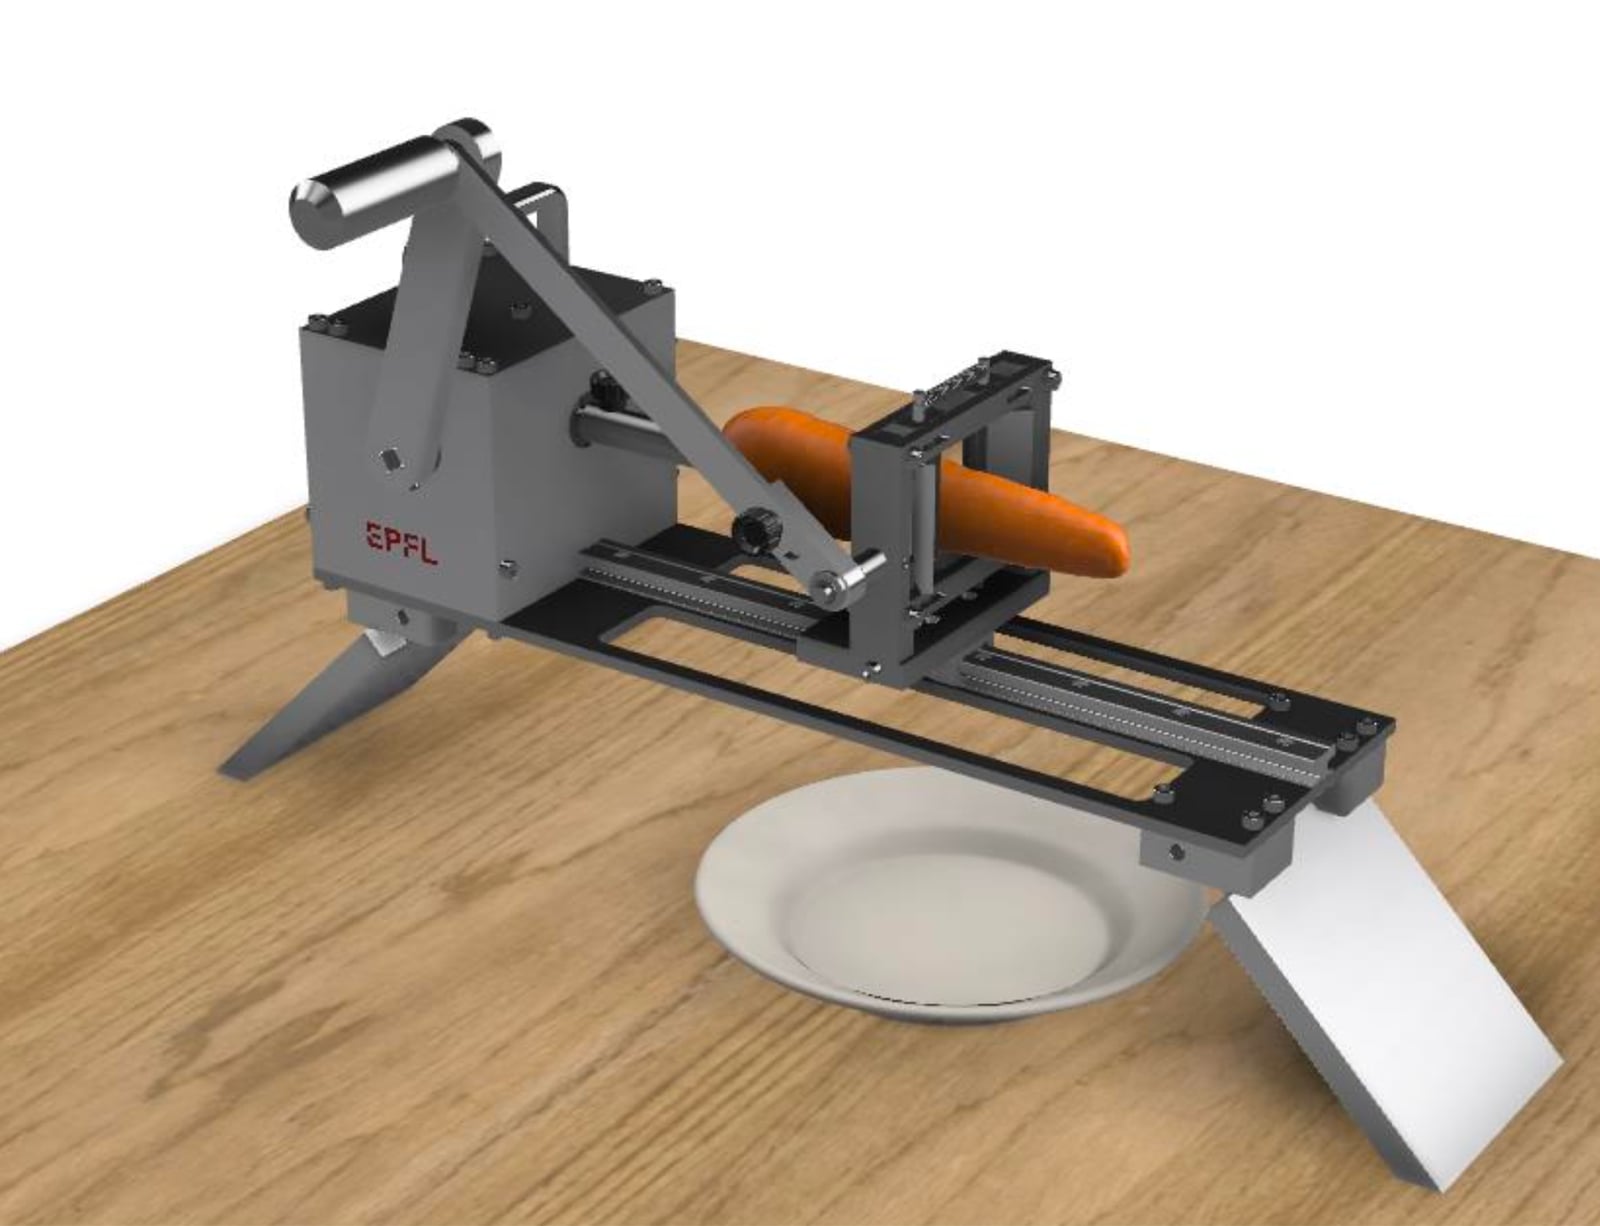
A hand-cranked carrot peeler where a rail-mounted blade carriage strips the carrot on the return stroke, while a partial gear indexes its rotation on the forward stroke.
My Implementation (The How)
Scored four mechanism concepts (ring-drive, Geneva, pendulum, and the chosen crank-rocker) against a weighted matrix, then modeled the kinematics and produced full 2D/3D technical drawings for machining.
Role
Duration: Spring 2022
Design Team Lead (Course Project)
Le Duplo
A pocket paragliding variometer, packaged inside a 3D-printed Duplo brick.
Embedded Systems & Electronics · Personal
Context (The Why)
Paragliding pilots need to hear whether they're climbing or sinking without looking at a screen mid-flight.
Solution (The What)
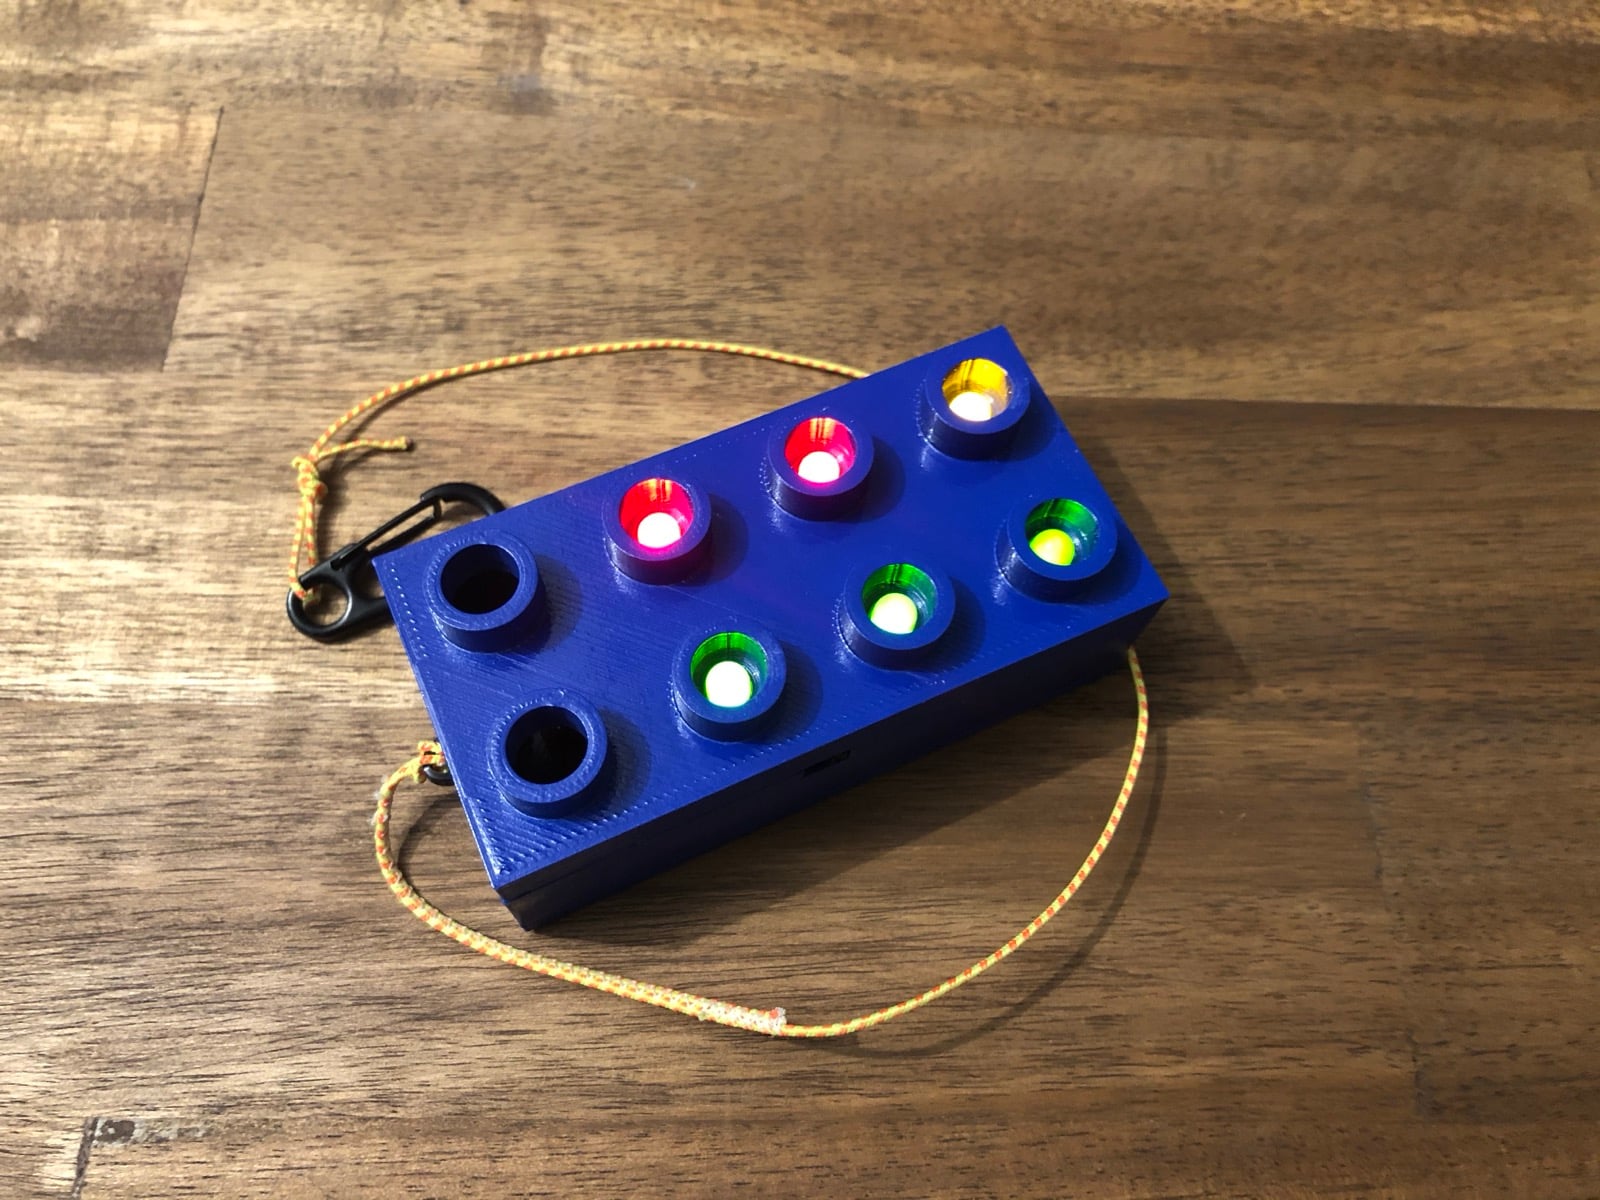
A pocket-sized paragliding variometer packaged in a 3D-printed case shaped like an oversized Duplo brick, sensing climb or sink rate through a barometric pressure sensor.
My Implementation (The How)
Designed a custom PCB with a pressure sensor, an accelerometer, and an Arduino Nano and adapted a friend's variometer firmware to the new hardware.
Role
Duration: Spring 2021
Hardware Designer (Personal Project)
TimiT - Connected Door Lock
A WiFi-controlled door lock, built from scratch as a Swiss high-school engineering thesis.
Embedded Systems & Electronics · Academic
Context (The Why)
I wanted a WiFi-controlled door lock for my bedroom and needed a high-school engineering thesis.
Solution (The What)
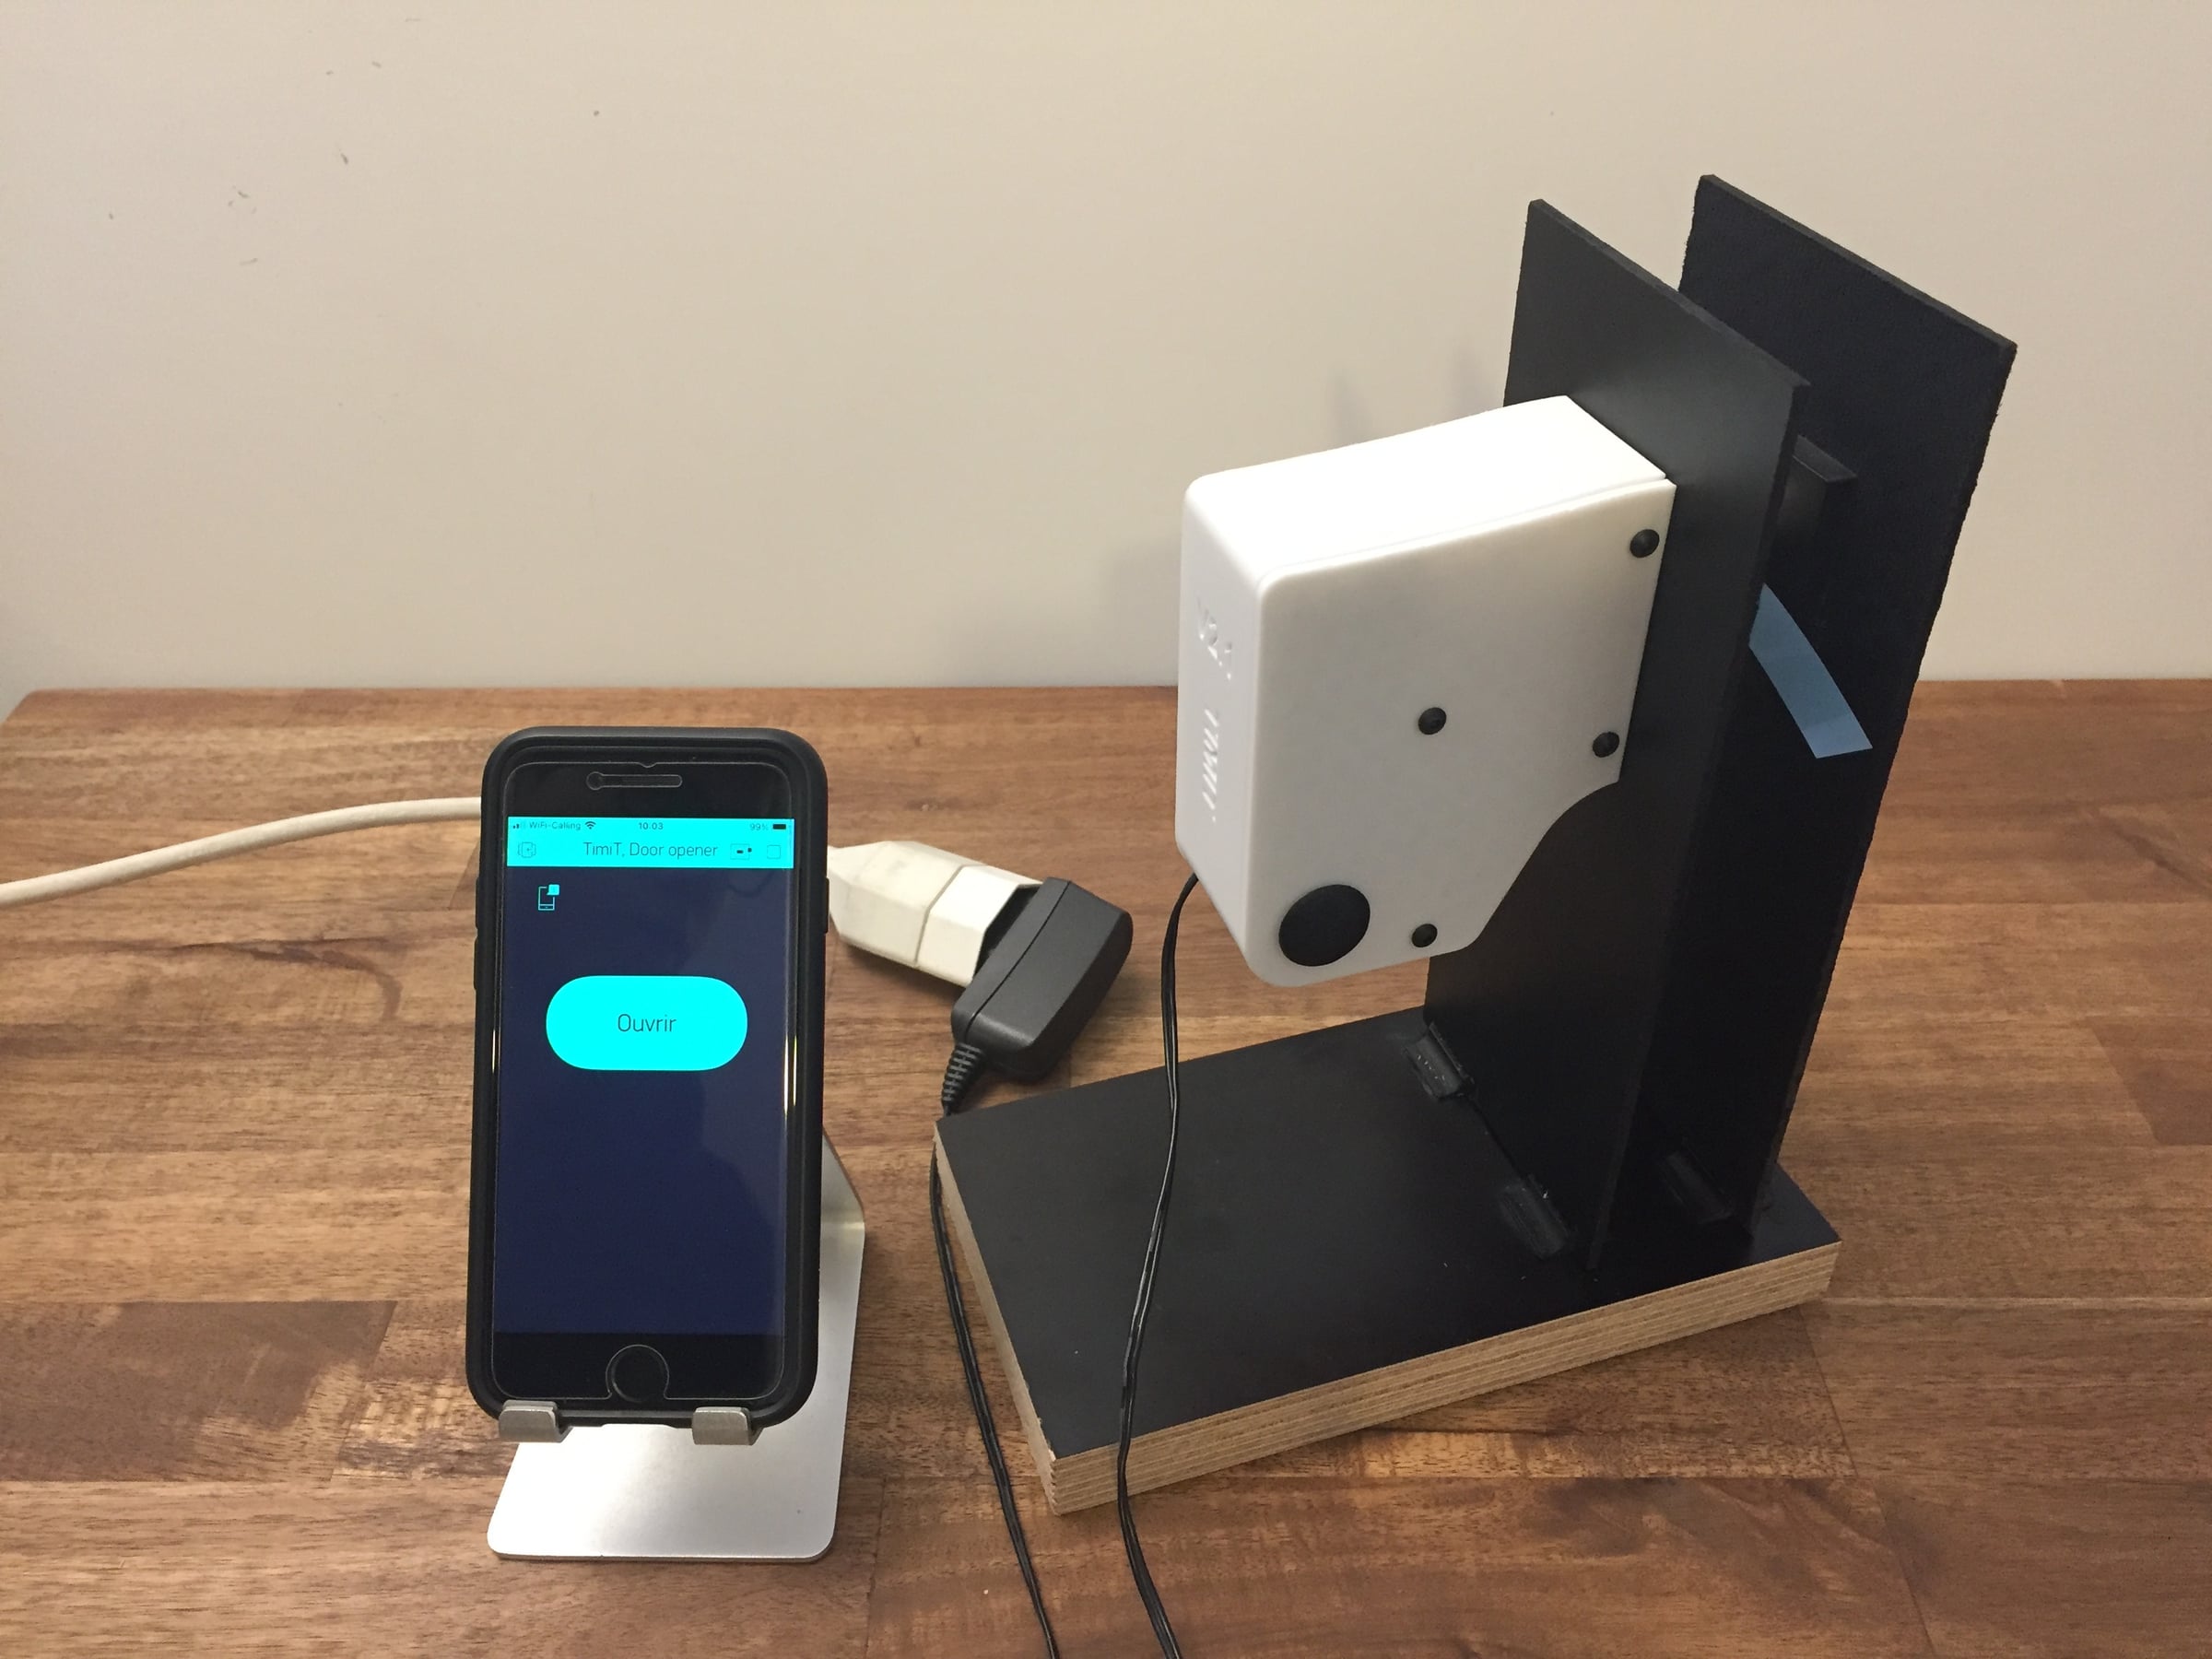
A WiFi-connected door lock: a high-torque DC motor and 3D-printed housing clamp onto the existing latch, controlled from a smartphone app.
My Implementation (The How)
Measured the latch's real torque need, drove a geared DC motor through H-bridge, wrote the ESP8266 firmware, and designed and 3D-printed the clamp-on housing over nine months.
Role
Duration: 2020 – 2021
Mechatronics Developer
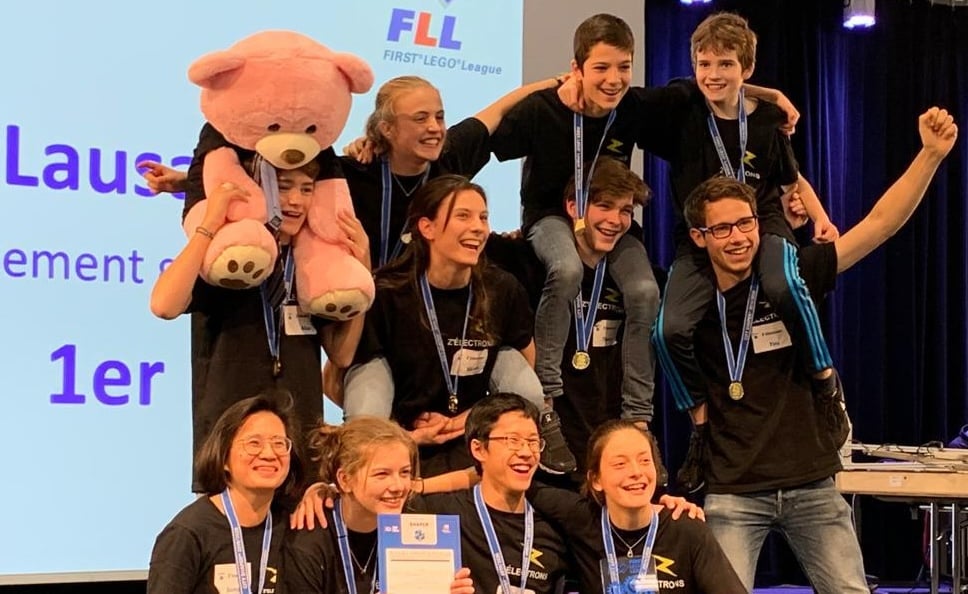
FIRST LEGO League
LEGO Mindstorms student competition
Robotics & Autonomous Control · Academic
Context (The Why)
FIRST LEGO League pairs a robot-game tournament with a parallel innovation project to teach teens the engineering process.
Solution (The What)
An autonomous LEGO Mindstorms EV3 robot that completed a series of timed missions.
My Implementation (The How)
Built and iterated the EV3 robot with swappable mechanical attachments for each mission and programmed autonomous routines to navigate and execute them within the round's time limit.
Role
Duration: 2019 – 2020
Robot Design & Programming